Products

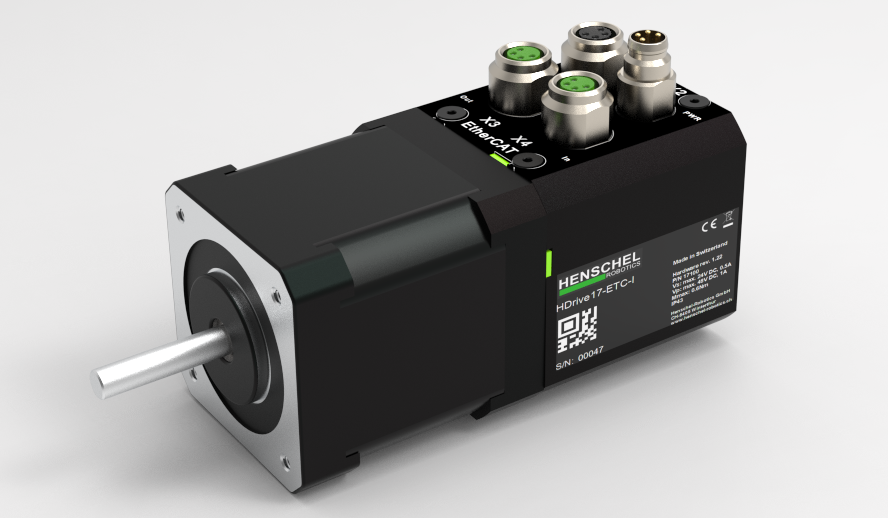
Released HDrive models for Ethernet (PC) and EtherCAT (PLC). Fully integrated servo units: motor, electronics, encoder and control in one housing.

HDrive17-ETH

NEMA17 · Ethernet

HDrive17-ETH

Compact integrated servo for developers, labs and PC-based machines. Communicates over standard Ethernet from Python, C#, C++, Java or Matlab. Built-in web server for setup and monitoring. No PLC required.

  • FlangeNEMA17 (42 mm)
  • Dimensions42 × 42 × 88 mm
  • Stall torque0.6 Nm
  • Max speed~700 RPM
  • Supply12-24 V DC
  • Max current / power1.0 A / 24 W
  • InterfacesEthernet, CAN, Step/Dir, PWM
  • Control modesPosition, velocity, torque
  • Encoder14-bit magnetic absolute
  • Accuracy±0.1°
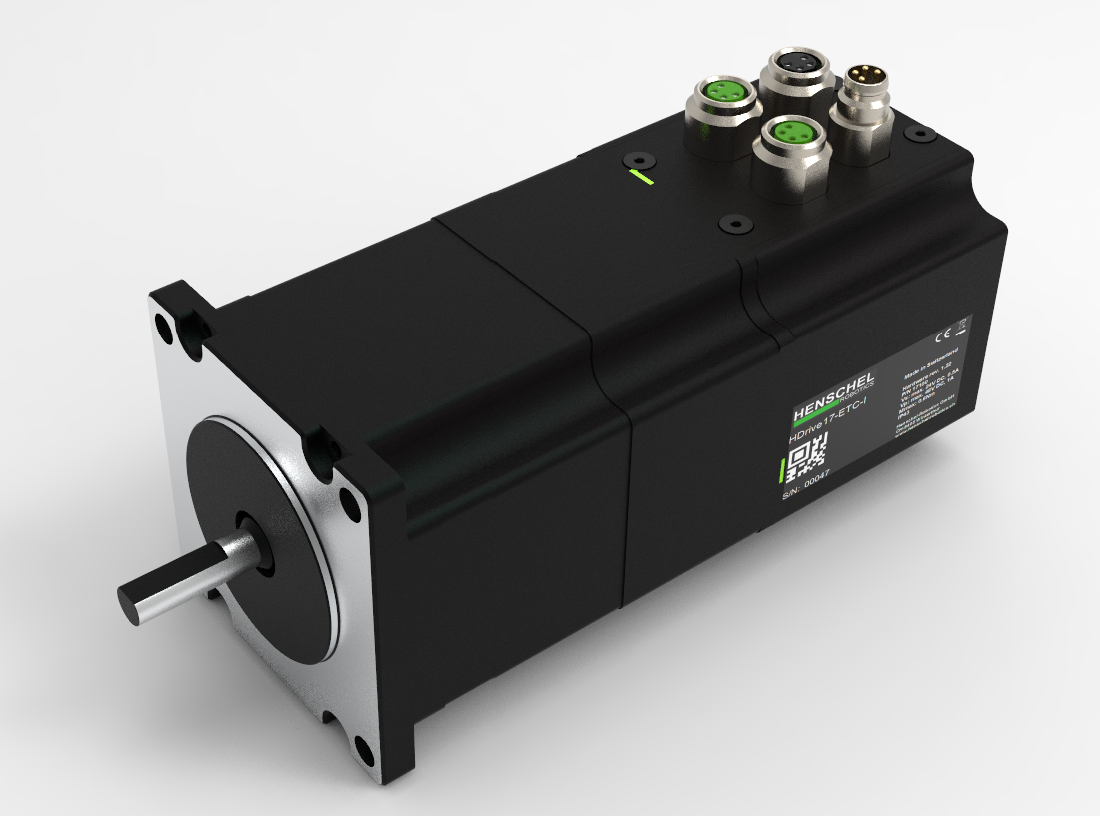
HDrive17-ETC

NEMA17 · EtherCAT

HDrive17-ETC

Industrial EtherCAT servo for PLC-based automation. CiA 402 drive profile, FoE firmware updates and cycle times down to 50 µs. Separate supply rails for logic (Vs) and power stage (Vp, up to 48 V).

  • FlangeNEMA17 (42 mm)
  • Dimensions42 × 42 × 88 mm
  • Stall torque0.6 Nm
  • Max speed @48 Vup to ~2200 RPM
  • Vs / Vp12-24 V / 12-48 V DC
  • Max Vp current / power1.0 A / ~36 W
  • ProtocolEtherCAT 100 Mbps, CiA 402
  • ConnectorsM8 power, ECAT In/Out, I/O
  • Firmware updateFoE (Bootstrap)
HDrive23-ETC

NEMA23 · EtherCAT

HDrive23-ETC

NEMA23 EtherCAT servo with higher torque and the same industrial stack as the HDrive17-ETC. For axes that need more stall torque without giving up full integration.

  • FlangeNEMA23 (56 mm)
  • Dimensions56 × 56 × 120 mm
  • Stall torque2.2 Nm
  • Max speed @48 V~1500 RPM
  • Vs / Vp12-24 V / 12-48 V DC
  • Max Vp current / power2.0 A / ~70 W
  • ProtocolEtherCAT 100 Mbps, CiA 402
  • Firmware updateFoE (Bootstrap)

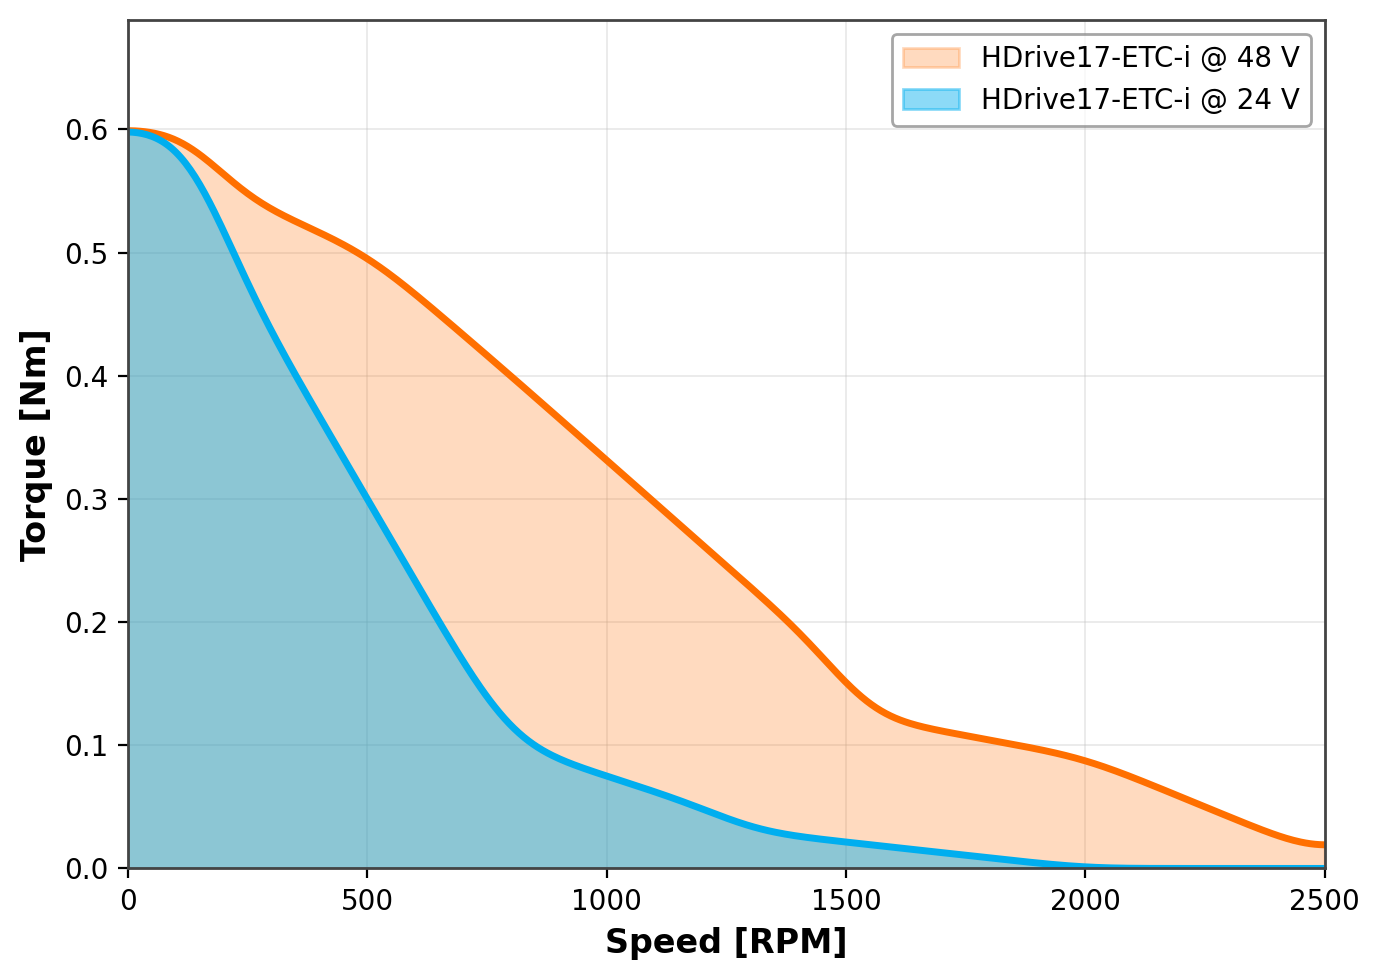
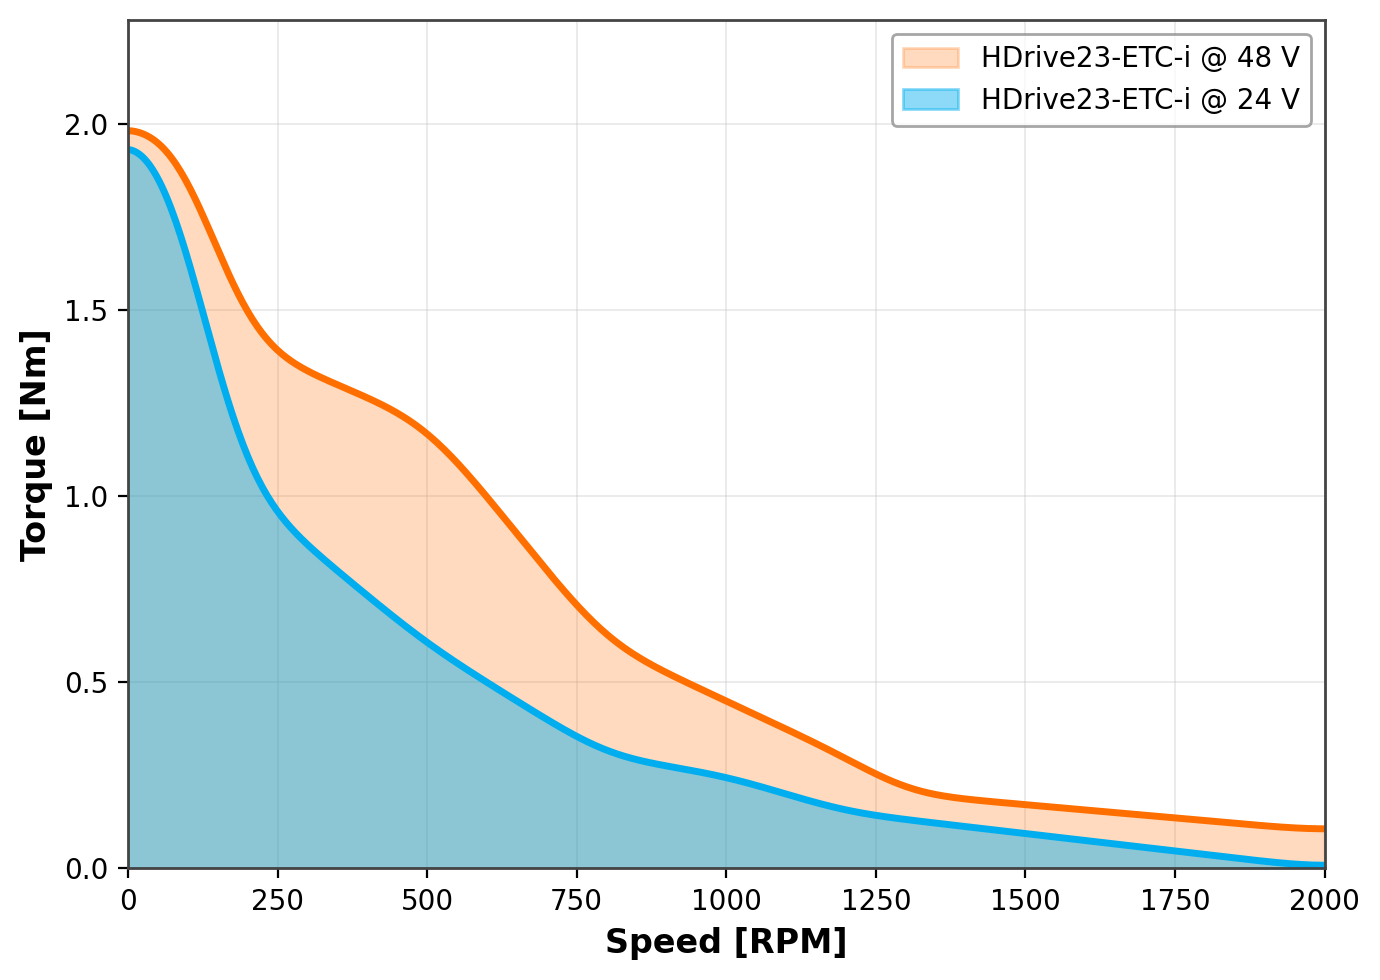
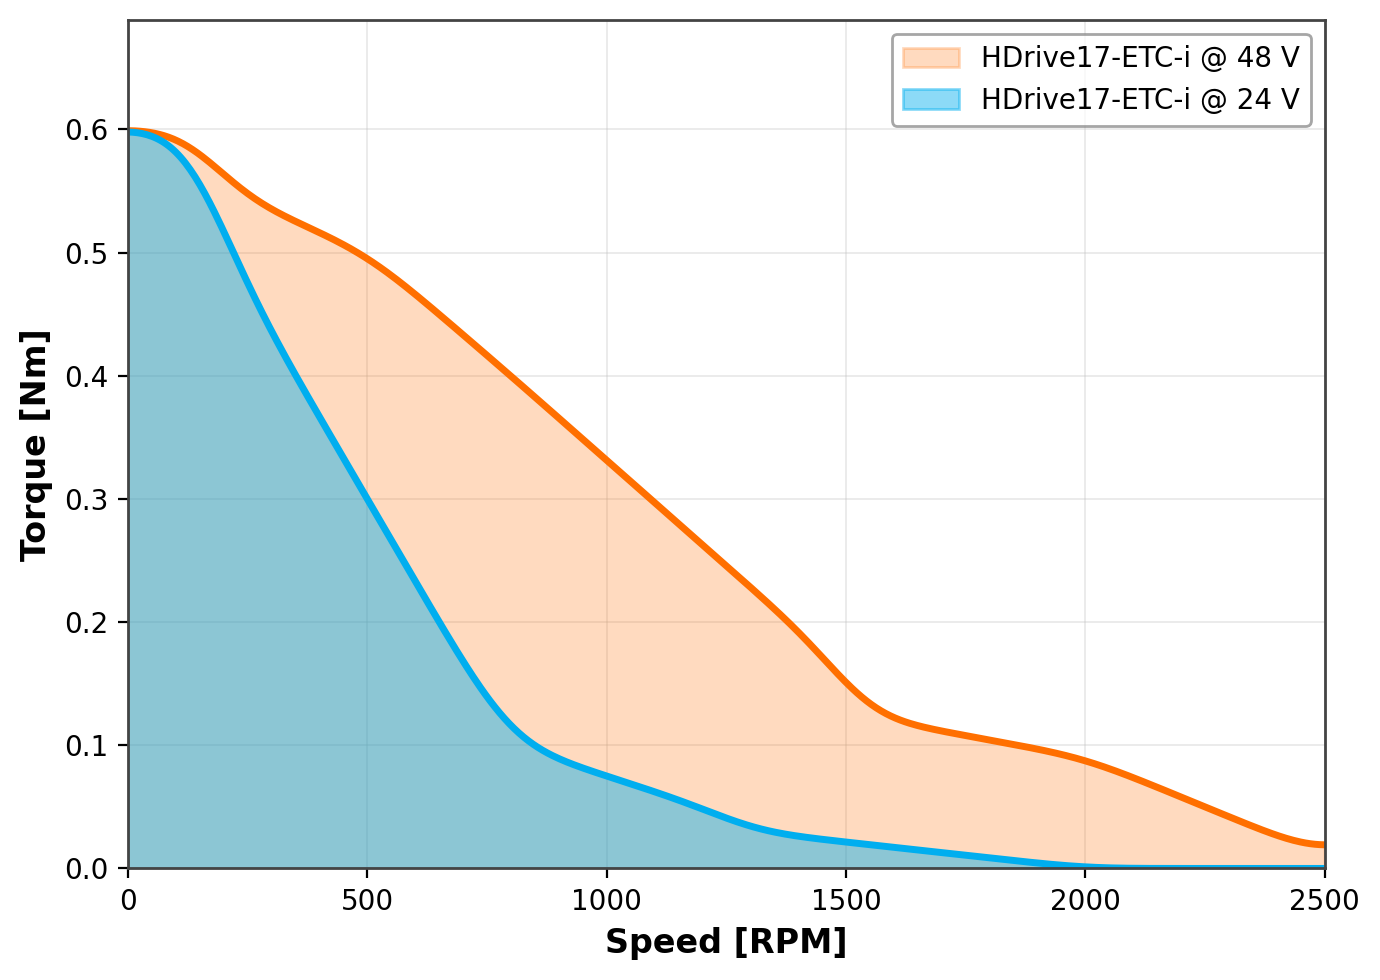
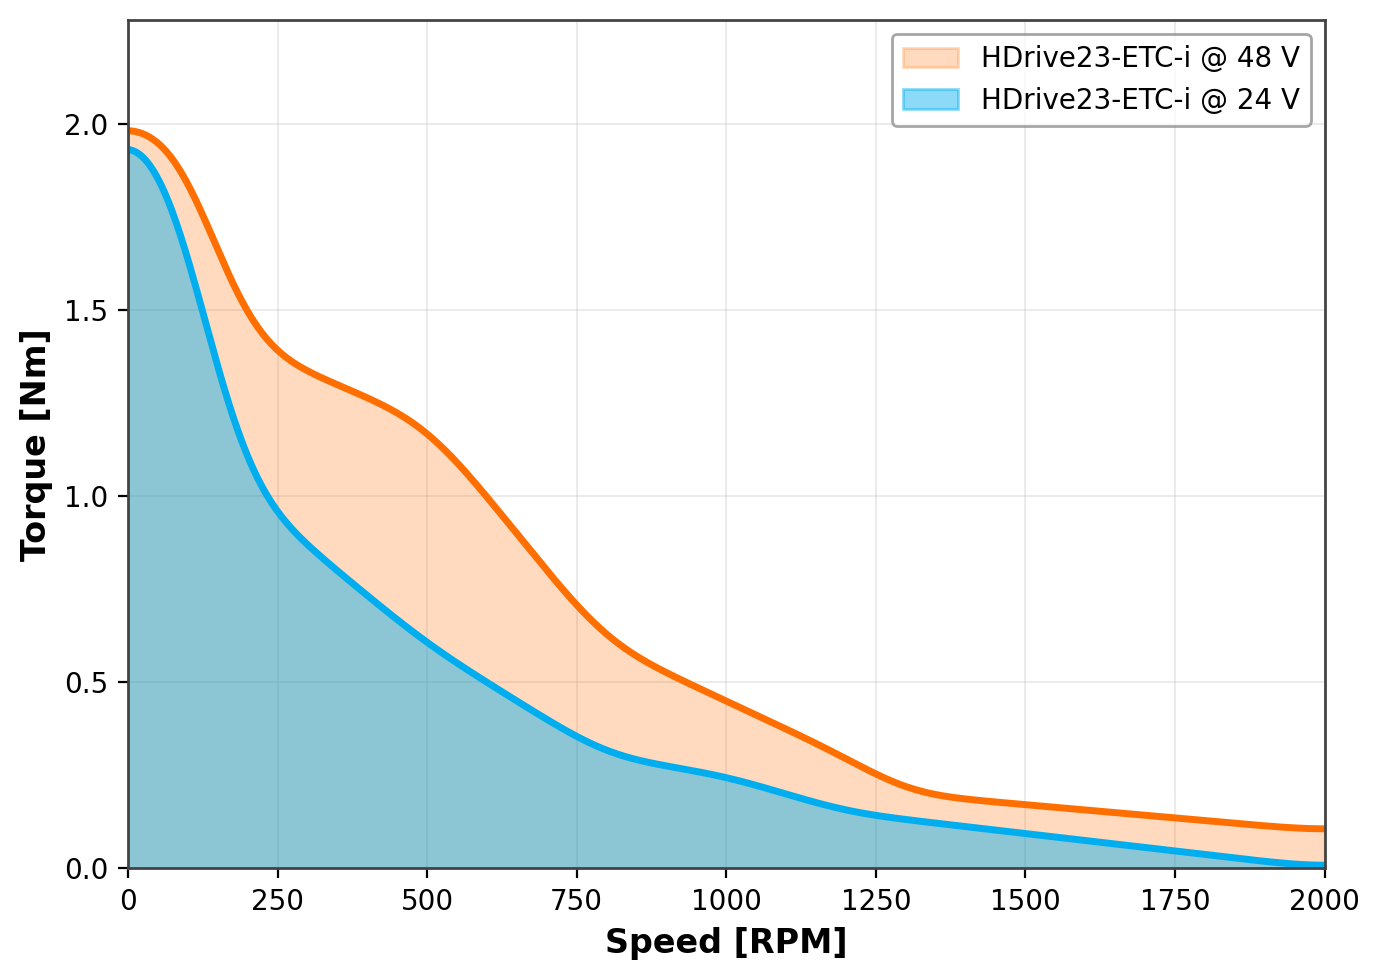
Torque / speed curves

Typical operating envelopes of the EtherCAT HDrive models. Each curve is available as a PNG download.

HDrive17-ETC

NEMA17 · Vs/Vp up to 24 V / 48 V · stall torque 0.6 Nm

HDrive17-ETC torque vs speed curve Download PNG

HDrive23-ETC

NEMA23 · Vs/Vp up to 24 V / 48 V · stall torque 2.2 Nm

HDrive23-ETC torque vs speed curve Download PNG

Quick comparison

Ethernet for PC control, EtherCAT for PLC-based industrial systems.

HDrive17-ETH HDrive17-ETC HDrive23-ETC
Description Servo with Ethernet Servo with EtherCAT Servo with EtherCAT
Size 42 × 42 × 88 mm 42 × 42 × 88 mm 56 × 56 × 120 mm
Speed ~700 RPM ~2200 RPM (48 V) ~1500 RPM (48 V)
Stall torque 0.6 Nm 0.6 Nm 2.2 Nm
Voltage 12-24 V 24 V / 48 V 24 V / 48 V
Protocol Ethernet TCP/IP EtherCAT EtherCAT
Typical host PC / Python PLC PLC

Common to all models: closed-loop FOC, position / velocity / torque modes, 14-bit magnetic encoder, ±0.1° accuracy, IP40, CE, Swiss Made.